Recognised & Supported by
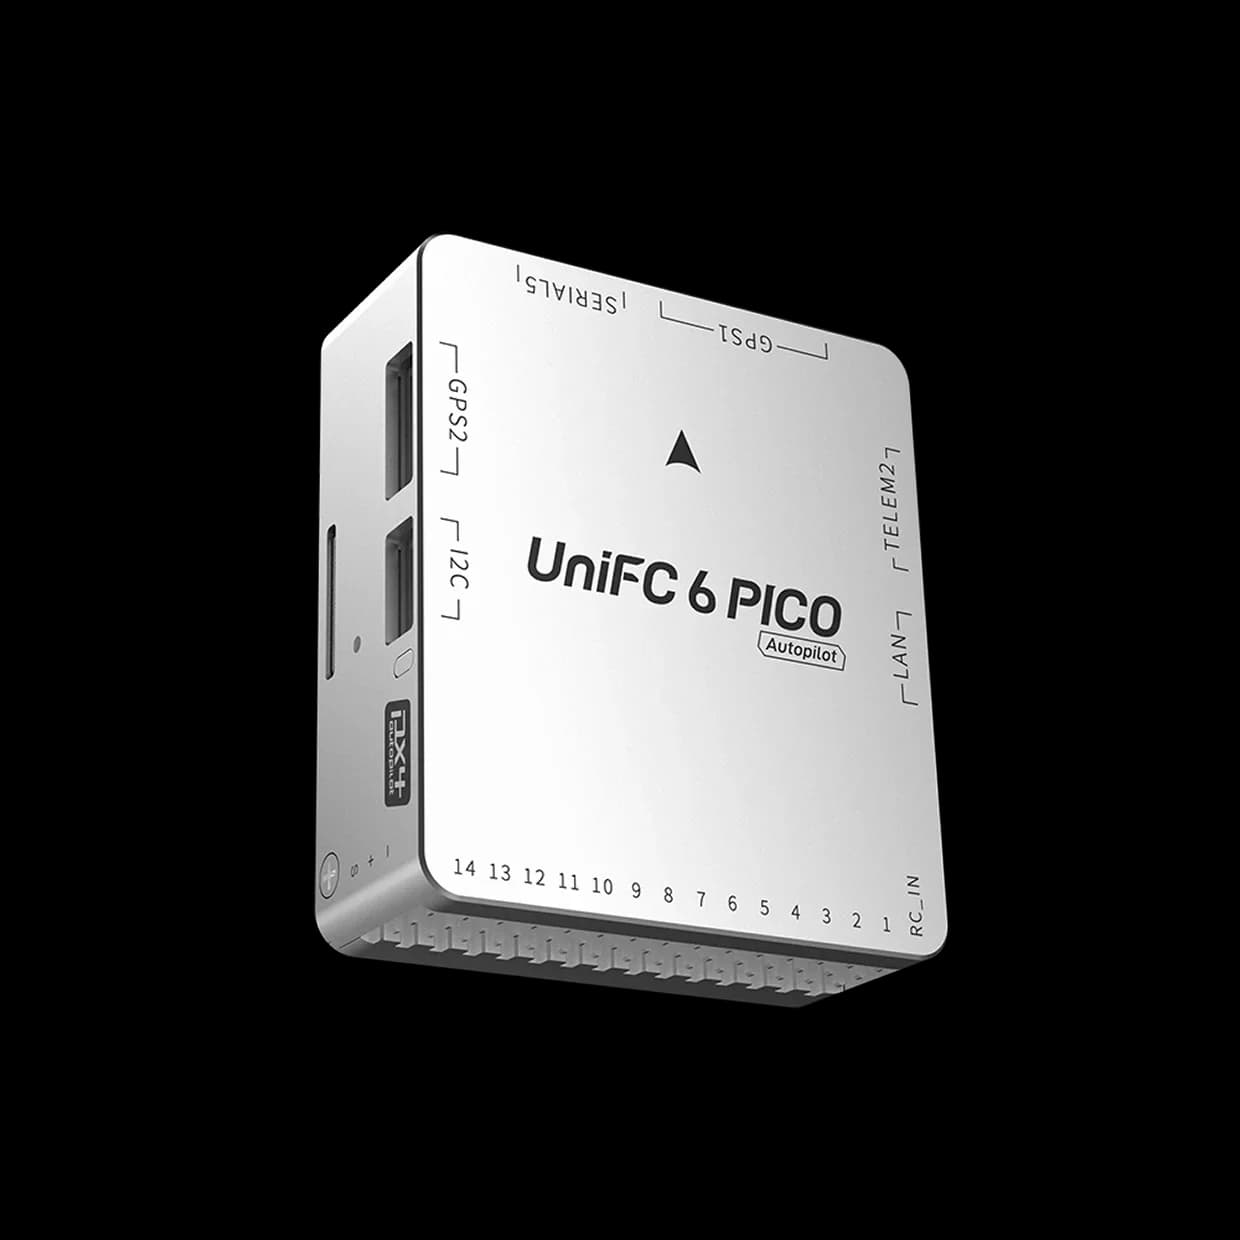
The SIYI UniFC 6 PICO is a compact industrial-grade autopilot and flight controller designed for UAV and unmanned-system applications. It combines high-performance processing, redundant flight sensors, multiple communication interfaces, and compatibility with the ArduPilot and PX4 ecosystems.
The UniFC 6 PICO is powered by the STM32H743IIK6 ARM Cortex-M7 processor operating at 480 MHz, with 2 MB Flash and 1 MB RAM. This provides the processing platform required for advanced flight-control and autonomous-system applications.
For flight sensing, the controller incorporates a dual-IMU and dual-barometer architecture. The specified sensors include ICM45686 and BMI088 IMUs, two ICP20100 barometers, and an IST8310 magnetometer. The controller also incorporates an IMU heating resistor.
The UniFC 6 PICO provides a range of interfaces for integrating flight-control and peripheral systems, including:
Bidirectional DShot is supported on PWM channels 1–8, while channels 13–14 do not support DShot.
The flight controller is designed for open-source autopilot ecosystems including ArduPilot and PX4. The SIYI manual also references Mission Planner and SIYI UniGCS as supported ground-control software.
UniFC 6 PICO can be configured for a variety of unmanned platforms, including:
The integrated 100 Mbps Ethernet interface enables network-based communication with compatible systems. The manual describes Ethernet configuration for MAVLink communication over TCP/UDP, making it suitable for connected UAV and robotics applications.
The controller can also be integrated with compatible SIYI payload equipment, such as the A8 mini gimbal, through Ethernet-based connectivity.
With dimensions of approximately 49 × 42.6 × 16.2 mm and a weight of approximately 40 g, the UniFC 6 PICO is designed for compact UAV and unmanned-system installations where space and weight are important considerations. Its power port operates at 4.5–5.5 V.
Flight data can be recorded using the onboard TF/MicroSD card, while the controller provides configurable DataFlash logging and telemetry logging options.
For reliable operation, the flight controller should be mounted close to the vehicle's centre of gravity, with its orientation aligned correctly with the vehicle. GPS/GNSS equipment should be positioned with a clear view of the sky and away from motors, ESCs, batteries and high-current wiring.
The UniFC 6 PICO does not have built-in vibration damping. For high-vibration platforms, the manual recommends using an appropriate external damping solution and ensuring that motors, propellers and mounting structures are properly secured and balanced.
For official government agricultural guidelines, scheme updates, and research initiatives, please visit the National Agriculture Portal. Click here →


